ros2arduino
ros2arduino
0
Components
Hardware components
WIZnet - W5500
x 1

Arduino - Arduino MKR2UNO Adapter
x 1
Project description
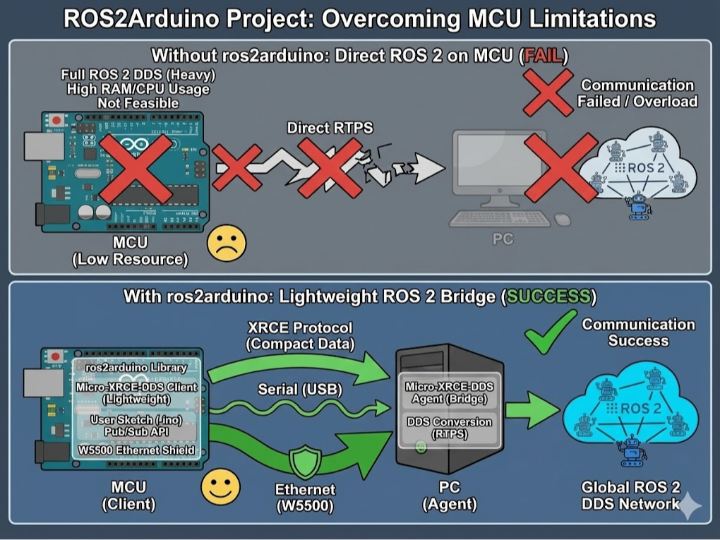
1. 프로젝트 개요 (Executive Summary) 프로젝트명: ros2arduino 개발 주체: ROBOTIS (로보티즈) 핵심 정의: Arduino 환경에서 Micro-XRCE-DDS 기술을 활용하여, MCU를 ROS 2(Robot Operating System 2) 네트워크의 정식 노드(Node)로 참여시키는 라이브러리입니다. 기술적 포지셔닝: **공식 micro-ROS**가 복잡하고 무거운 "표준 프레임워크"라면, **ros2arduino**는 아두이노 사용자가 가장 쉽고 빠르게 DDS 통신을 구현할 수 있도록 만든 **"경량화된 래퍼(Wrapper) 라이브러리"**입니다. 2. 소프트웨어 아키텍처 및 동작 원리 이 프로젝트를 이해하기 위해서는 **"왜 MCU는 PC처럼 직접 통신하지 못하는가?"**를 이해해야 합니다. 이를 해결하는 구조가 Client-Agent 모델입니다. A. 시스템 구성도 (The Bridge Model) MCU(아두이노)는 자원이 부족하여 거대한 ROS 2 네트워크(Global Data Space)에 직접 접속할 수 없습니다. 따라서 중간에 '통역사' 역할을 하는 Agent가 필요합니다. MCU (Client)…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

