SabertoothMicroROSBridge
micro-ROS bridge on RP2040 + WIZnet W6100 forwarding ROS2 cmd_vel to a Sabertooth 2x60 motor driver, with Ethernet UDP transport planned.
0
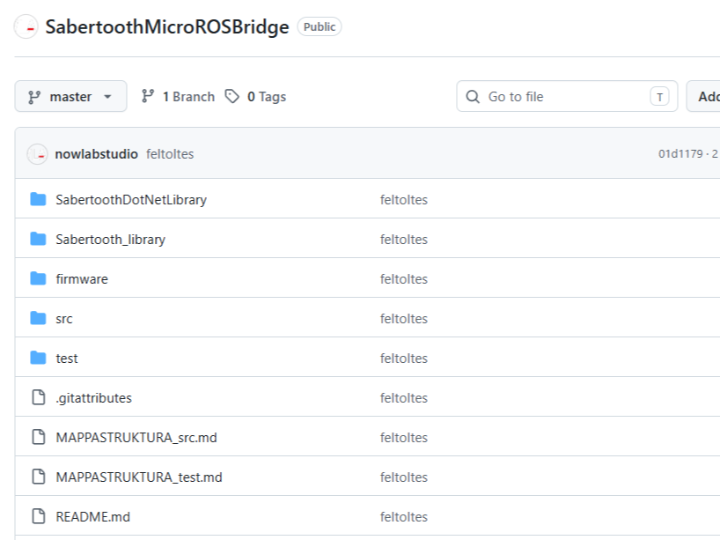
Project description
Bridging ROS2 and Sabertooth with W6100-EVB-Pico — SabertoothMicroROSBridge Summary "A micro-ROS bridge on RP2040 + WIZnet W6100 that forwards ROS2 cmd_vel commands to a Sabertooth motor driver — currently running over USB Serial, with W6100 Ethernet UDP transport planned as the next step." This project appears to be the work of Nowlab, a rapid prototyping studio based in Budapest, Hungary. The GitHub profile (nowlabstudio) lists Nowlab as the affiliated organization, and the other repositories follow the same theme of industrial automation and robot control. Whether this is an official…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

