How to Bridge Physical I/O into ROS 2 with W6100 on RP2040?
This project uses a WIZnet W6100 EVB Pico as a wired microcontroller-to-ROS 2 bridge: Zephyr runs on the RP2040, micro-ROS carries messages over UDP
0
Components
Hardware components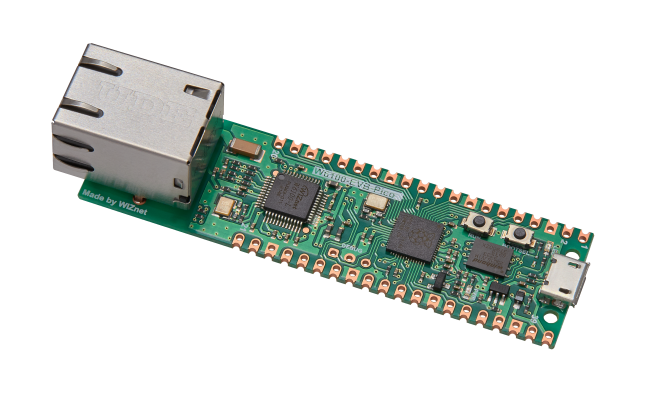
WIZnet - W6100-EVB-Pico
x 1

Project description
Summary This project uses a WIZnet W6100 EVB Pico as a wired microcontroller-to-ROS 2 bridge: Zephyr runs on the RP2040, micro-ROS carries messages over UDP, and the board exposes attached inputs and actuators as ROS 2-facing channels. In practical terms, the W6100 is the Ethernet side of the system, the RP2040 handles device logic, and the software stack turns GPIO, ADC, RC PWM, and safety inputs into configurable ROS-connected interfaces. AI generated image What the Project Does The repository describes itself as a universal ROS 2 bridge for microcontrollers and targets the W6100 EVB Pico…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

