[CASIA / Zhongke Siji] Universal Humanoid Five-Finger Dexterous Hand — TCP/IP Ethernet (W5500) Integ
이 사례는 중국과학원 자동화연구소(CASIA)가 2024년 5월 23일 출원하고 같은 해 10월 11일 등록한 발명특허 CN118269127B "Universal Humanoid Five-Finger Dexterous Hand"를 다룹니다
0
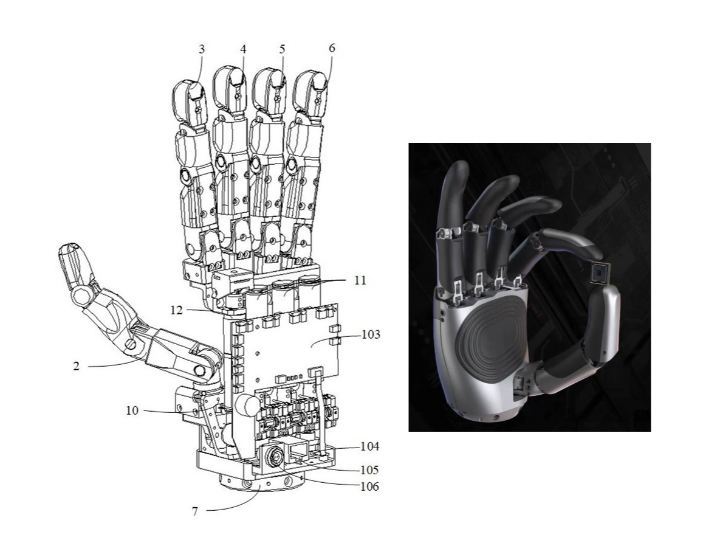
Project description
📌 Overview 이 사례는 중국과학원 자동화연구소(CASIA)가 2024년 5월 23일 출원하고 같은 해 10월 11일 등록한 발명특허 CN118269127B "Universal Humanoid Five-Finger Dexterous Hand"를 다룹니다. 특허가 공개한 시스템은 palm support 내부에 5개 손가락의 tendon rope driving unit을 모두 집적한 humanoid dexterous hand이며, 손 내부의 control module(STM32 F4 main control chip 탑재 제어 board)과 host computer(industrial PC) 사이의 명령·피드백 전달을 W5500 Ethernet controller chip이 담당합니다. 명세서는 기구 설계(rotation/flexion 관절과 tendon routing), tactile·joint sensor 구성, speed/position control mode, 그리고 W5500 기반 TCP/IP 통신 아키텍처까지를 포함합니다. 기술적으로 의미 있는 지점은 두 가지입니다. 하나는 deep learning·path planning·autonomous…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

