How to Build a Wired micro-ROS Node Network with W5500 on RP2040 for a ROS2 Robot?
SAINT.OS (in the input-inc/saintos repository) is a ROS2-based control system for a distributed mobile robot.
0
Components
Hardware components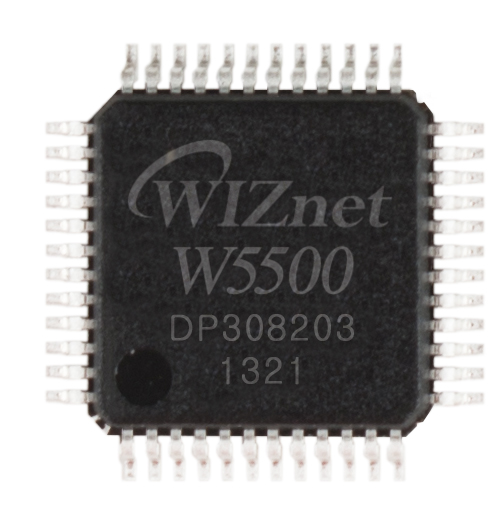
WIZnet - W5500
x 1


Raspberry Pi - RP2040
x 1
Project description
Summary SAINT.OS (in the input-inc/saintos repository) is a ROS2-based control system for a distributed mobile robot, with a Raspberry Pi “server” coordinating multiple peripheral nodes (head, arms, tracks). WIZnet’s W5500 is used on RP2040-class microcontroller nodes to provide wired Ethernet, enabling a custom micro-ROS transport over UDP with DHCP and socket handling via WIZnet ioLibrary—so the internal robot network can stay deterministic and isolated from the external “operator/admin” network. What the Project Does SAINT.OS is positioned as an operating system for a track-based mobile…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

