How Does AutoAimCombatBot Combine Mecanum Drive, Vision Tracking, and W5500 Web Status?
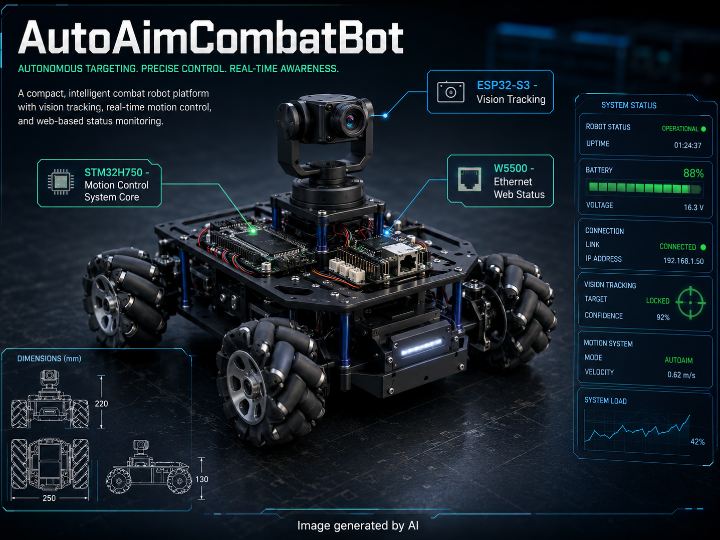
A dual-chip STM32H750 and ESP32-S3 combat robot platform that combines mecanum drive, visual auto-aim gimbal control, and W5500-based web status monitoring.
0
Project description
📌 Overview AutoAimCombatBot is a dual-chip mecanum wheel combat robot platform based on STM32H750XBH6 and ESP32-S3. The STM32H750 side handles real-time chassis control, encoder feedback, PS2 gamepad input, servo gimbal control, LCD display, and W5500-based web status monitoring. The ESP32-S3 side handles camera-based visual tracking and sends PAN/TILT angle commands to the STM32 through I2C. The project is modeled around a RoboMaster-style small combat robot concept, but its technical value is broader than the theme. It shows how a real-time MCU, a vision processor, and an Ethernet…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

