Why Does a W5500 Ethernet Link Carry ROS 2 Drive Commands in the ULSTU Buggy?
ULSTU put a W5500 on the ESP32 board of its Ackermann teaching robot, so a Jetson AGX Xavier sends JSON-RPC drive commands and reads IMU data over wired UDP.
0
Components
Hardware components
WIZnet - W5500
x 1

Ethernet controller on the ULSTU low-level control board. Carries ROS 2 drive commands from a Jetson AGX Xavier to the ESP32 as JSON-RPC over UDP port 9090, and returns IMU samples on the same port. T
Project description
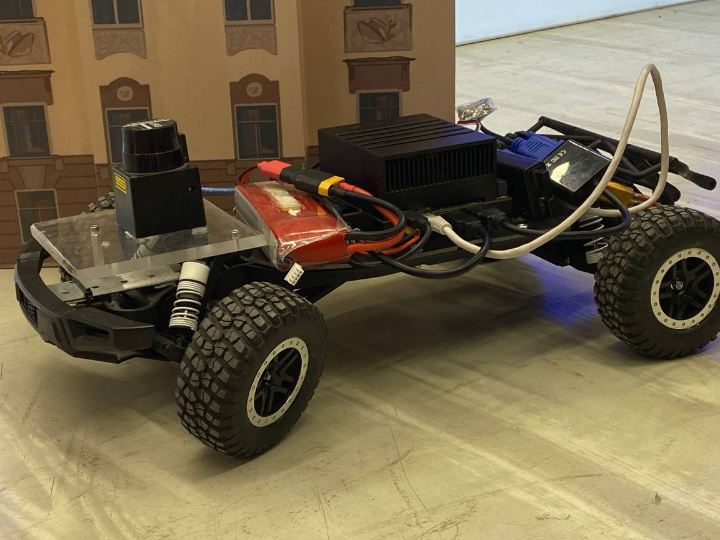
📌 An Ackermann Teaching Robot From Ulyanovsk State Technical University Ulyanovsk State Technical University created the buggy-learn repository on GitHub on 2025-04-05, and the low-level control board of the robot inside it carries a WIZnet W5500 Ethernet controller. The GitHub organisation ulstu lists its location as Ulyanovsk, Russia and its contact address as fist@ulstu.ru. The repository is MIT licensed, copyright 2025 Ulyanovsk State Technical University, with commits from k.svyatov@ulstu.ru and the account ghub-ayrtom, the last of them on 2025-04-11. The assembled robot. The scanning…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

