MATE-ROV-2025
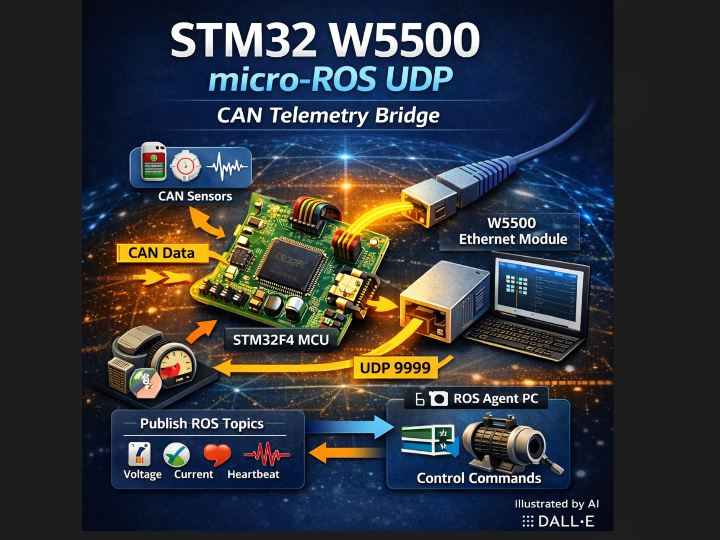
STM32F4 firmware uses a W5500 Ethernet module to exchange micro-ROS messages over UDP (port 9999) and bridge CAN sensor data to ROS topics.
0
Project description
STM32F4 + WIZnet W5500 — micro-ROS UDP Communication Bridge This STM32F4 firmware collects CAN sensor telemetry and publishes it to ROS topics using micro-ROS over UDP. Ethernet connectivity is implemented with a WIZnet W5500 module through the LoayEthernet library. The system bridges CAN frames into ROS messages while receiving control commands such as pump triggers from a micro-ROS agent. What This Project Does This firmware acts as a CAN-to-ROS telemetry bridge. It runs on an STM32F4 microcontroller and performs three main tasks: receiving sensor and system telemetry over CAN, converting…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

