CMVC_B: STM32F407-Based ROV Control Firmware with W5500 UDP Communication
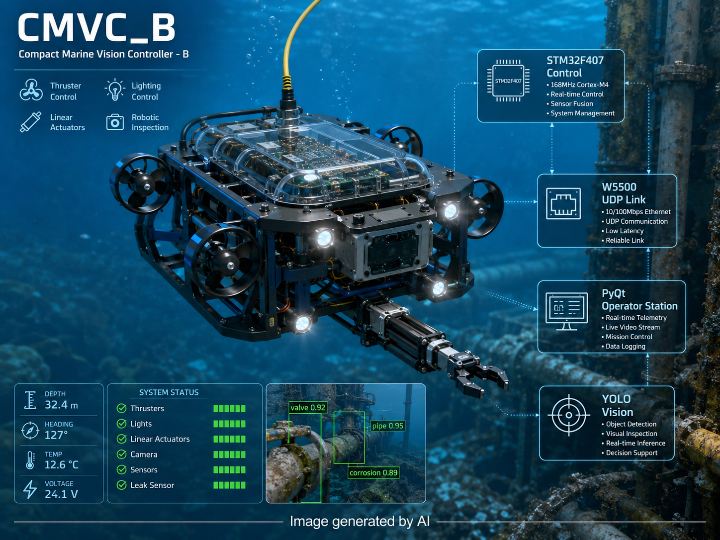
A+n underwater ROV control workspace combining STM32F407 actuator firmware, a PyQt operator station, YOLO-based barnacle vision, and a W5500 UDP FW path.
0
Project description
Project Overview CMVC_B is a comprehensive engineering workspace for an underwater robot, or ROV, built around an STM32F407 control board. The repository is organized into three main lines: embedded firmware, a PC-side operator station, and a barnacle vision module. The embedded line progresses from module-level tests to integrated actuator firmware and a separate W5500 UDP communication firmware path. The PC-side line provides a PyQt operator interface, gamepad input, UDP command transmission, and safety arbitration through RobotBrain. The vision line covers underwater image preprocessing…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

