Let's Make Your Underwater Drones - A Foundation for Sensor-Based Mobility Project
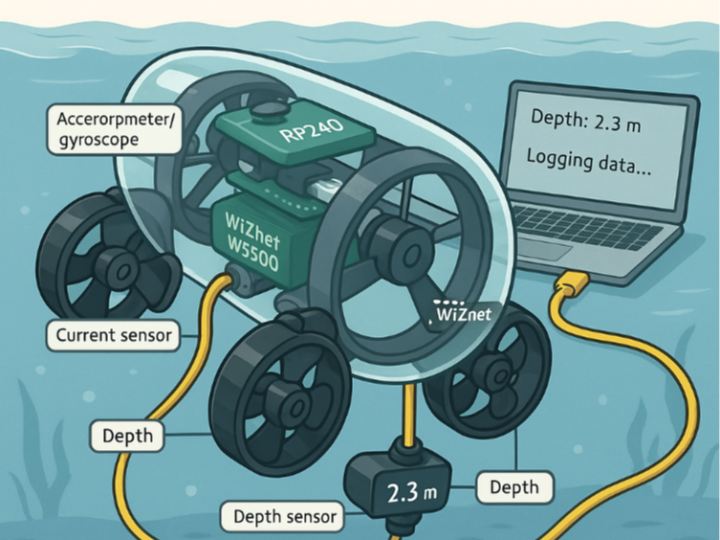
This project provides an automatic depth control and sensor logging system for an underwater drone. But it's more than just a drone controller.
0
Components
Hardware components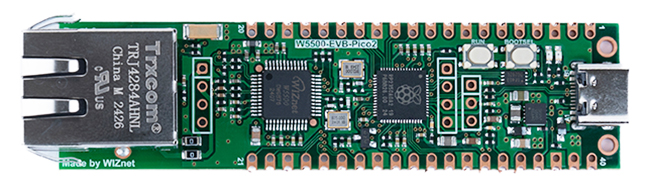
WIZnet - W5500-EVB-Pico2
x 1

Project description
This project provides an automatic depth control and sensor logging system for an underwater drone. But it's more than just a drone controller — it demonstrates a solid architecture for a wide range of sensor-based mobility systems (e.g., underwater ROVs, ground robots, autonomous platforms). With features like sensor integration, multicore processing, real-time control, and a UART-based command interface, this structure can be directly adapted for various maker applications. 🧠 Key Features Overview Feature Description Auto Depth Control Maintains target depth using pressure sensor and PID…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

