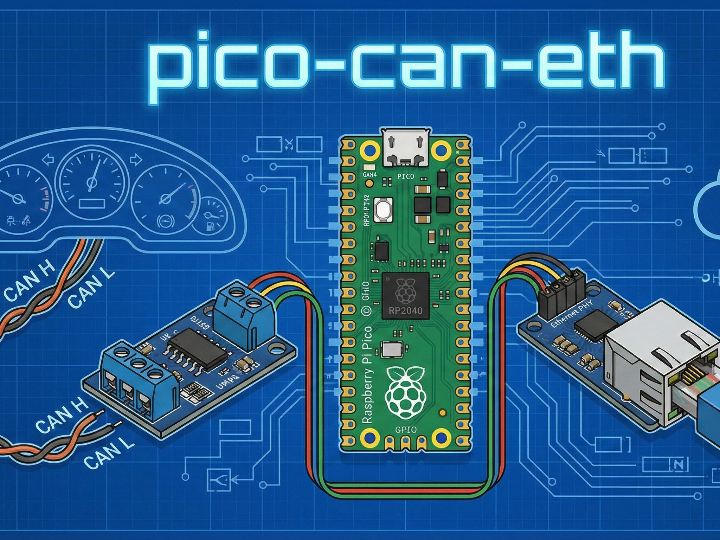
A bidirectional CAN bus to Ethernet/WiFi bridge implementation for the Raspberry Pi Pico W
A bidirectional CAN bus to Ethernet/WiFi bridge implementation for the Raspberry Pi Pico W written in Rust using the Embassy async framework.
0
Project description
What this project does This repository implements a bidirectional gateway between a CAN bus and a UDP multicast network. On the CAN side, it targets an MCP2515 SPI CAN controller configured for 250 kbps, which is a common “maker-to-industrial” pattern because it keeps the CAN controller external and cheap. On the network side, it forwards CAN frames over UDP multicast (group 224.1.1.1, port 8888) using a compact payload format: CAN_ID (4 bytes, big-endian) LENGTH (1 byte, 0–8) DATA (0–8 bytes) The README also documents UART-based configuration and flash-stored Wi-Fi credentials, making it…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

