Roland Hauff – Lawnmower Robot ESPrtk uBlox ZED-F9P , Cube Orange Autopilot ESP32 RTK
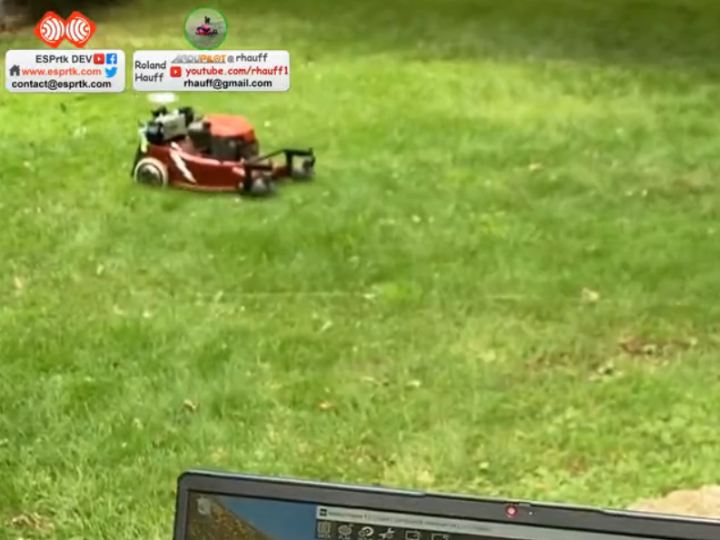
The mower I used is an old 21" gas powered push mower, with 8" Hoverboard motors installed for the drive. An Odrive 3.6 56V drives the brush
13
Project description
Hardware. App Build : NTRIP/MQTT RTK BaseStation+Rover+CASTER ESP32 : ESP32 DEV KIT C Espressif ( ESP32_WROOM_32U or ESP32_WROOM_32UE CHIP) RTK GNSS: F9P or PX1122R Display: OLED SSD1306 0.96 inch or SH1106 1.3 inch( option !) Ethernet: W5500 ( option !) Power supply: 5V 2.5A Adapter Other: LED , Button, Switch , 2.4Ghz WiFi Antenna , GNSS RTK Antenna, RJ45 Etheret cable, Micro USB Cable , 3.3V Active Buzzer , … If you want to build your own RTK Base station, read more here (Full instructions, connection diagram, how to configure): NTRIP RTK Basestation – PX1122R / F9P + ESP32 + TRIMBLE…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.