zenoh-ros2-nostd
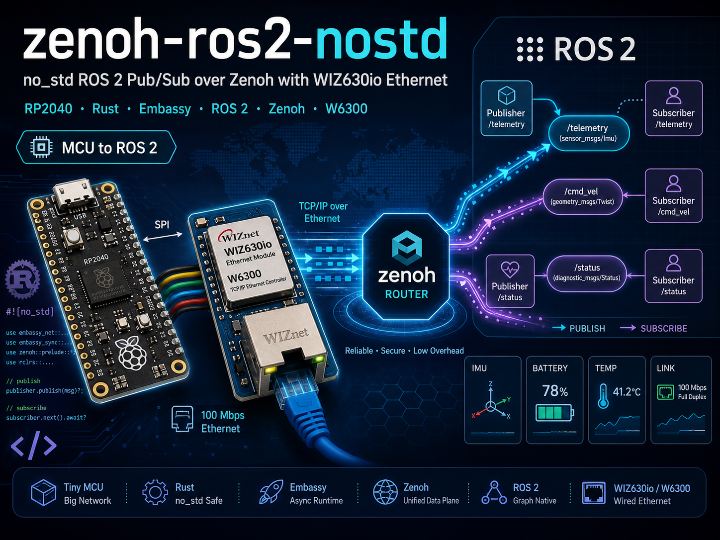
A no_std Rust library that lets MCU nodes publish and subscribe to ROS 2 topics over Zenoh, demonstrated with RP2040 + WIZ630io Ethernet.
0
Project description
zenoh-ros2-nostd — no_std ROS 2 Pub/Sub over Zenoh with WIZ630io Ethernet PROJECT DESCRIPTION 📌 Overview zenoh-ros2-nostd is a Rust no_std library for implementing ROS 2 topic pub/sub on embedded MCUs. The project uses CDR serialization over Zenoh Protocol v9 and is designed to communicate with standard ROS 2 nodes using rmw_zenoh_cpp. The README describes it as a no_std ROS 2 topic pub/sub library for embedded MCUs. A ROS 2 topic is the basic publish/subscribe communication mechanism used by ROS 2 nodes. It is commonly used for continuous data streams such as sensor readings, robot states…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.