Scaled Position-Force Tracking for Wireless Teleoperation of Miniaturized Surgical Robotic System
Miniaturized surgical robotic system presents promising trend for reducing invasiveness during operation.
10
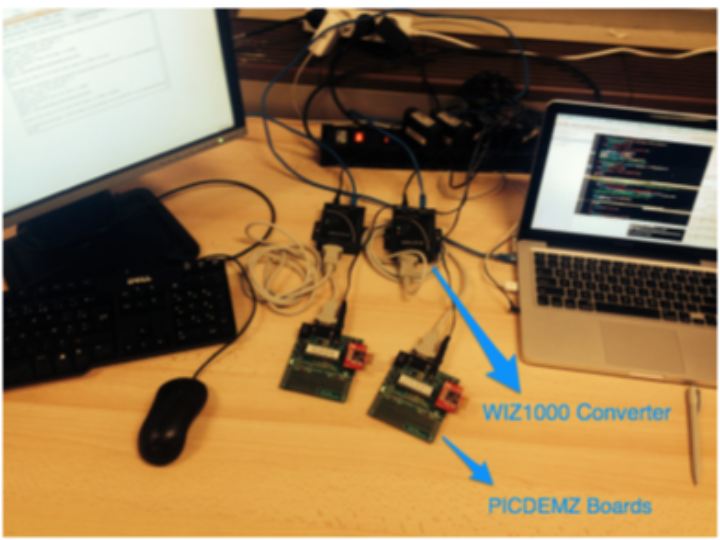
Miniaturized surgical robotic system presents promising trend for reducing invasiveness during operation.
10
Share projects and connect with makers.
Joined before the site update? first.
New to WIZnet Makers?
We sent a verification link to your address. Open it to activate your account, then log in.
Accounts from this email provider are reviewed by an administrator after verification. Approval usually takes one business day.
Already have an account?
Enter your email address. If it belongs to an account, we'll send a link to set a new password. Members who joined before the site update use this to set their password.
If an account uses that address, we sent a link to set a new password. The link works once and expires in 30 minutes.
Know your password?
Need an account?
