W5500-Based ESP32-S3 micro-ROS Node Suite for a Distributed Rover Control System
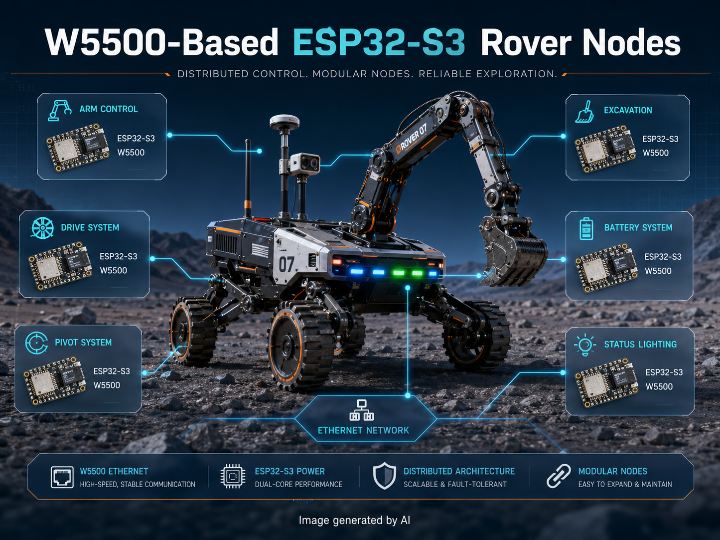
Five ESP32-S3 nodes connect ROS 2 to rover motors, BMS telemetry, and status LEDs through W5500 Ethernet and micro-ROS.
0
Project description
Project Overview 2026_ESP_Nodes is a collection of embedded firmware projects developed for the Swinburne Rover Team’s 2026 rover system. The repository separates the rover electronics into five ESP32-S3 nodes: Arm_ESP BMS_ESP Excavation_ESP Pivot_ESP Status_ESP Each directory is an independent PlatformIO project rather than a single multi-target firmware build. The nodes share a common foundation consisting of the Arduino framework, micro_ros_platformio, ROS 2 Jazzy configuration, custom micro-ROS transport, and the Arduino Ethernet library. The repository README also states that nodes…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

