


W5500-Based ESP32-S3 micro-ROS Node Suite for a Distributed Rover Control System
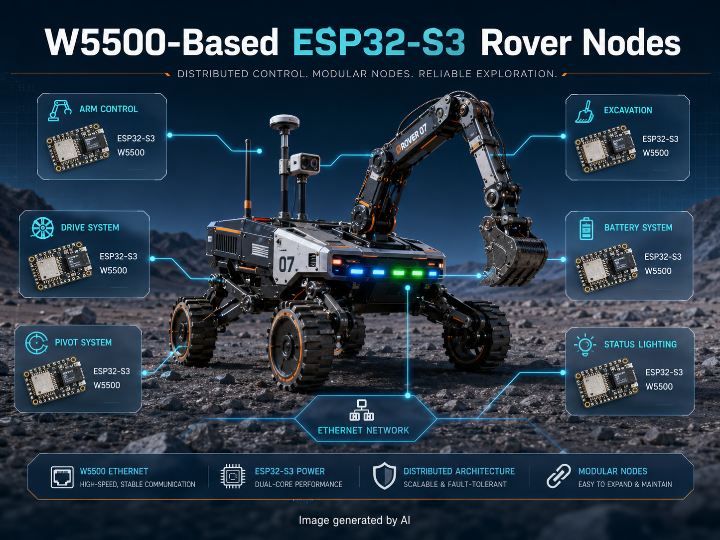
Five ESP32-S3 nodes connect ROS 2 to rover motors, BMS telemetry, and status LEDs through W5500 Ethernet and micro-ROS.

Reset Password
Know your password?
Need an account?
Five ESP32-S3 nodes connect ROS 2 to rover motors, BMS telemetry, and status LEDs through W5500 Ethernet and micro-ROS.