STM32H743 micro-ROS IMU Node over W5500 Ethernet
A PlatformIO-based STM32H743 IMU node publishes micro-ROS data over UDP through a W5500 hardware Ethernet socket path.
0
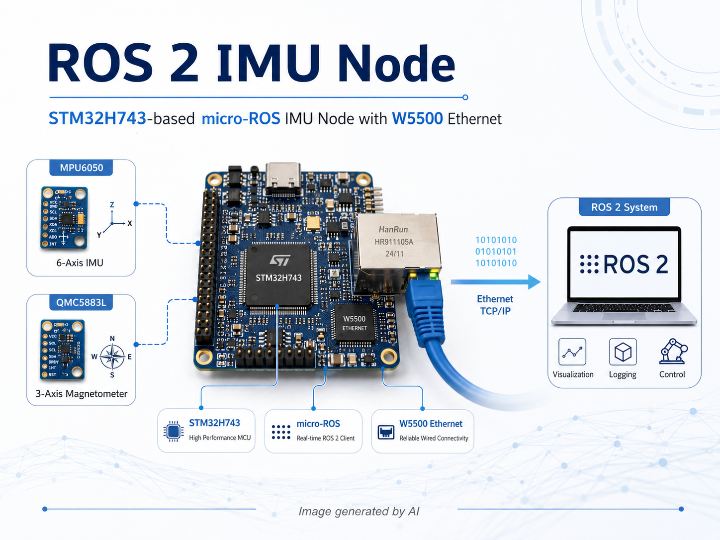
Project description
Project Overview microros-h7-pio is an embedded robotics reference implementation that connects an STM32H743-based sensor node to a ROS 2 system through wired Ethernet. The firmware samples inertial and magnetic sensors, calculates orientation data, and publishes the results as micro-ROS topics through a W5500 Ethernet controller. The repository targets ROS 2 Humble and uses PlatformIO with the Arduino framework. Item Implementation Project Type Embedded micro-ROS IMU and orientation sensor node Main MCU STM32H743, configured as devebox_h743vitx Build Environment PlatformIO, STM32 Arduino…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

