How Does a W5500 Modbus TCP BMS Connect a Rescue Robot Battery to ROS 2?
A Paderborn University lab BMS runs a Modbus TCP server on a W5500 hardware socket, port 502, so a ROS 2 node reads cell data and publishes BatteryState.
0
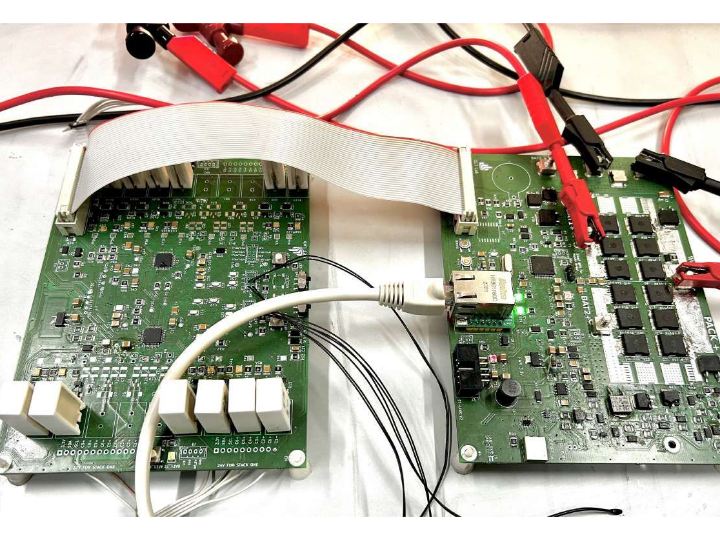
Project description
📝 Project Overview This project is an open-source hardware and software solution implementing an IoT-based Battery Management System (BMS) designed for applications such as Energy Storage Systems (ESS), Electric Vehicles (EVs), or remote off-grid power systems. Key features include: 1. Data Acquisition and Monitoring: Real-time measurement of voltage, current, and temperature for each battery cell to calculate the State of Charge (SoC) and State of Health (SoH). 2. Protection Control: Detection of hazardous conditions—such as over-charge, over-discharge, or overheating—triggers the control…
Keep reading with a free account
Guests can read 15 projects per visit. Log in or create a free account to read the full description, open the documents and join the comments.

